Every problem in the chapter beside the book’s answer, a chapter at a time as you scroll.
Chapter 9: Nonlinear systems
16 problems · 3 figuresExercise 8.1.101 §8.1 source ↗
Find the critical points and linearizations of the following systems.
a) , ,
b) , ,
c) , .
Answer
a) Critical points and . At using , the linearization is , . At using , the linearization is , .
b) Critical points and . At using , the linearization is , . At using , the linearization is , .
c) Critical point . Using , the linearization is , .
Exercise 8.1.102 §8.1 source ↗
Match systems
1) , ,
2) , ,
3) , ,
to the vector fields below. Justify.
a)
b)
c)
Answer
1) is c), 2) is a), 3) is b)
Exercise 8.1.103 §8.1 source ↗
The idea of critical points and linearization works in higher dimensions as well. You simply make the Jacobian matrix bigger by adding more functions and more variables. For the following system of 3 equations find the critical points and their linearizations:
Answer
Critical points are , and . The linearization at the origin using variables , , is , , . The linearization at the point using variables , , is , , .
Exercise 8.1.104 §8.1 source ↗
Any two-dimensional non-autonomous system , can be written as a three-dimensional autonomous system (three equations). Write down this autonomous system using the variables , , .
Answer
, , .
Exercise 8.2.101 §8.2 source ↗
For the systems below, find and classify the critical points.
a) ,
b) ,
c) ,
Answer
a) : saddle (unstable), : source (unstable), b) : spiral sink (asymptotically stable), : saddle (unstable), c) : saddle (unstable), : source (unstable)
Exercise 8.2.102 §8.2 source ↗
Find the implicit equations of the trajectories of the following conservative systems. Next find their critical points (if any) and classify them.
a)
b)
c)
Answer
a) , critical points: , an unstable saddle, and , a stable center. b) , no critical points. c) , critical point at is a stable center.
Exercise 8.2.103 §8.2 source ↗
The conservative system is not almost linear. Classify its critical point(s) nonetheless.
Answer
Critical point at . Trajectories are , for , these give closed curves around the origin, so the critical point is a stable center.
Exercise 8.2.104 §8.2 source ↗
Derive an analogous classification of critical points for equations in one dimension, such as based on the derivative. A point is critical when and almost linear if in addition . Figure out if the critical point is stable or unstable depending on the sign of . Explain. Hint: see § 1.6.
Answer
A critical point is stable if and unstable when .
Exercise 8.3.101 §8.3 source ↗
Take the damped nonlinear pendulum equation for some (that is, there is friction). Suppose the friction is large, in particular .
a) Find and classify the critical points.
b) Explain what your findings mean, and if it agrees with what you expect in reality.
Answer
a) Critical points are , for any integer . When is odd, we have a saddle point. When is even we get a sink. b) The findings mean the pendulum will simply go to one of the sinks, for example and it will not swing back and forth. The friction is too high for it to oscillate, just like an overdamped mass-spring system.
Exercise 8.3.102 §8.3 source ↗
Suppose we have the predator-prey system where the foxes are also killed at a constant rate ( foxes killed per unit time): .
a) Find the critical points and the Jacobian matrices of the system.
b) Put in the constants , , , , . Analyze the critical points. What do you think it says about the forest?
Answer
a) Solving for the critical points we get and . The Jacobian matrix at is whose eigenvalues are and . The eigenvalues are real of opposite signs and we get a saddle. (In the application, however, we are only looking at the positive quadrant so this critical point is irrelevant.) At we get Jacobian matrix . b) For the specific numbers given, the second critical point is the matrix is , which has eigenvalues . Therefore there is a spiral source; the solution spirals outwards. The solution eventually hits one of the axes, or , so something will die out in the forest.
Exercise 8.3.103 §8.3 source ↗
(challenging) Suppose the foxes never die. That is, we have the system . Find the critical points and notice they are not isolated. What will happen to the population in the forest if it starts at some positive numbers. Hint: Think of the constant of motion.
Answer
The critical points are on the line . In the positive quadrant the is always positive and so the fox population always grows. The constant of motion is . For any , this curve must hit the -axis (why?), so the trajectory will simply approach a point on the axis somewhere and the number of hares will go to zero.
Exercise 8.4.101 §8.4 source ↗
Show that the following systems have no closed trajectories.
a) ,
b) ,
c) .
Answer
Use Bendixson–Dulac Theorem. a) , so no closed trajectories. b) for all except the lines given by (where we get zero), so no closed trajectories. c) for all except the line given by (where we get zero), so no closed trajectories.
Exercise 8.4.102 §8.4 source ↗
Suppose an autonomous system in the plane has a solution , . What can you say about the system (in particular about limit cycles and periodic solutions)?
Answer
Using Poincaré–Bendixson Theorem, the system has a limit cycle, which is the unit circle centered at the origin, as , gets closer and closer to the unit circle. Thus , is the periodic solution.
Exercise 8.4.103 §8.4 source ↗
Show that the limit cycle of the Van der Pol oscillator (for ) must not lie completely in the set where . Compare with Figure 8.10.
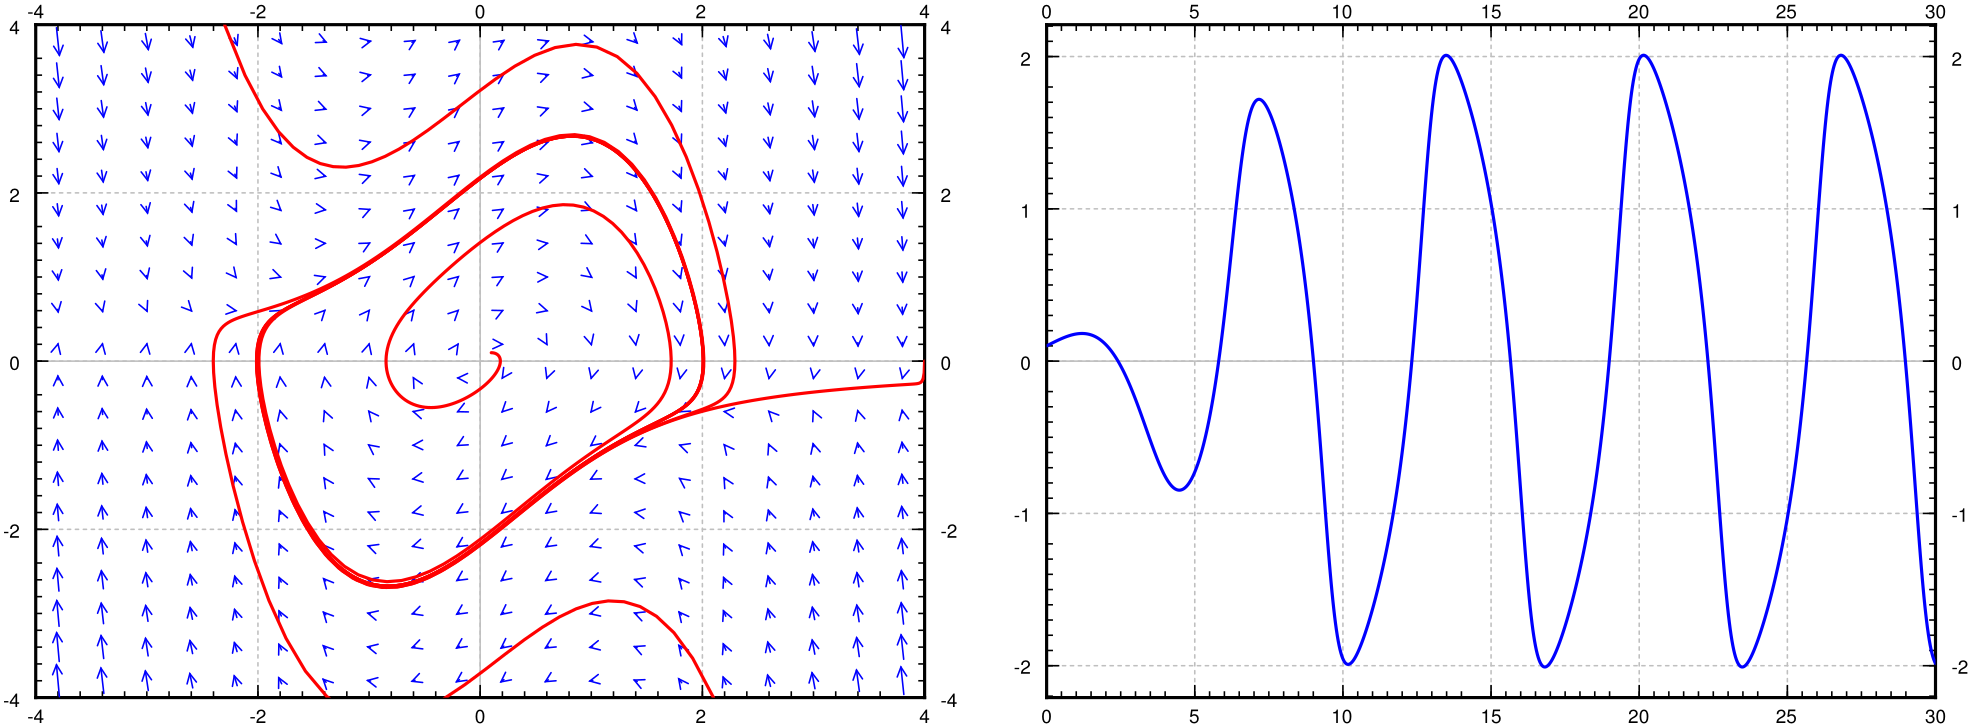
The phase portrait (left) and a graph of a sample solution of the Van der Pol oscillator.
Answer
, . So . The Bendixson–Dulac Theorem says there is no closed trajectory lying entirely in the set .
Exercise 8.4.104 §8.4 source ↗
Consider the system , given in polar coordinates. Find all the closed trajectories.
Answer
The closed trajectories are those where , therefore, all the circles centered at the origin with radius that is a positive multiple of are closed trajectories.
Exercise 8.5.101 §8.5 source ↗
Find critical points of the Lorenz system and the associated linearizations.
Answer
Critical points: , , . Linearization at using , , is , , . Linearization at using , , is , , . Linearization at using , , is , , .
Loading chapter 10…
Exercises and answers are adapted from Notes on Diffy Qs: Differential Equations for Engineers by Jiří Lebl, which is free to read and download, and are used under the CC BY-NC-SA 4.0 licence. They are taken from the book’s LaTeX source and set for the web, so they may differ slightly from the printed page. This adaptation is released under the same licence and is neither affiliated with nor endorsed by Lebl or Jiří Lebl.